APPLE TV · tvOSComing soon
 Oblique Lab
The backyard lab, on the big screen.
Use a Siri Remote to present seven backyard scenarios, explore the scene, and replay recorded robot-policy trials with their real outcomes. Designed for meetups, demonstrations, and sales conversations.
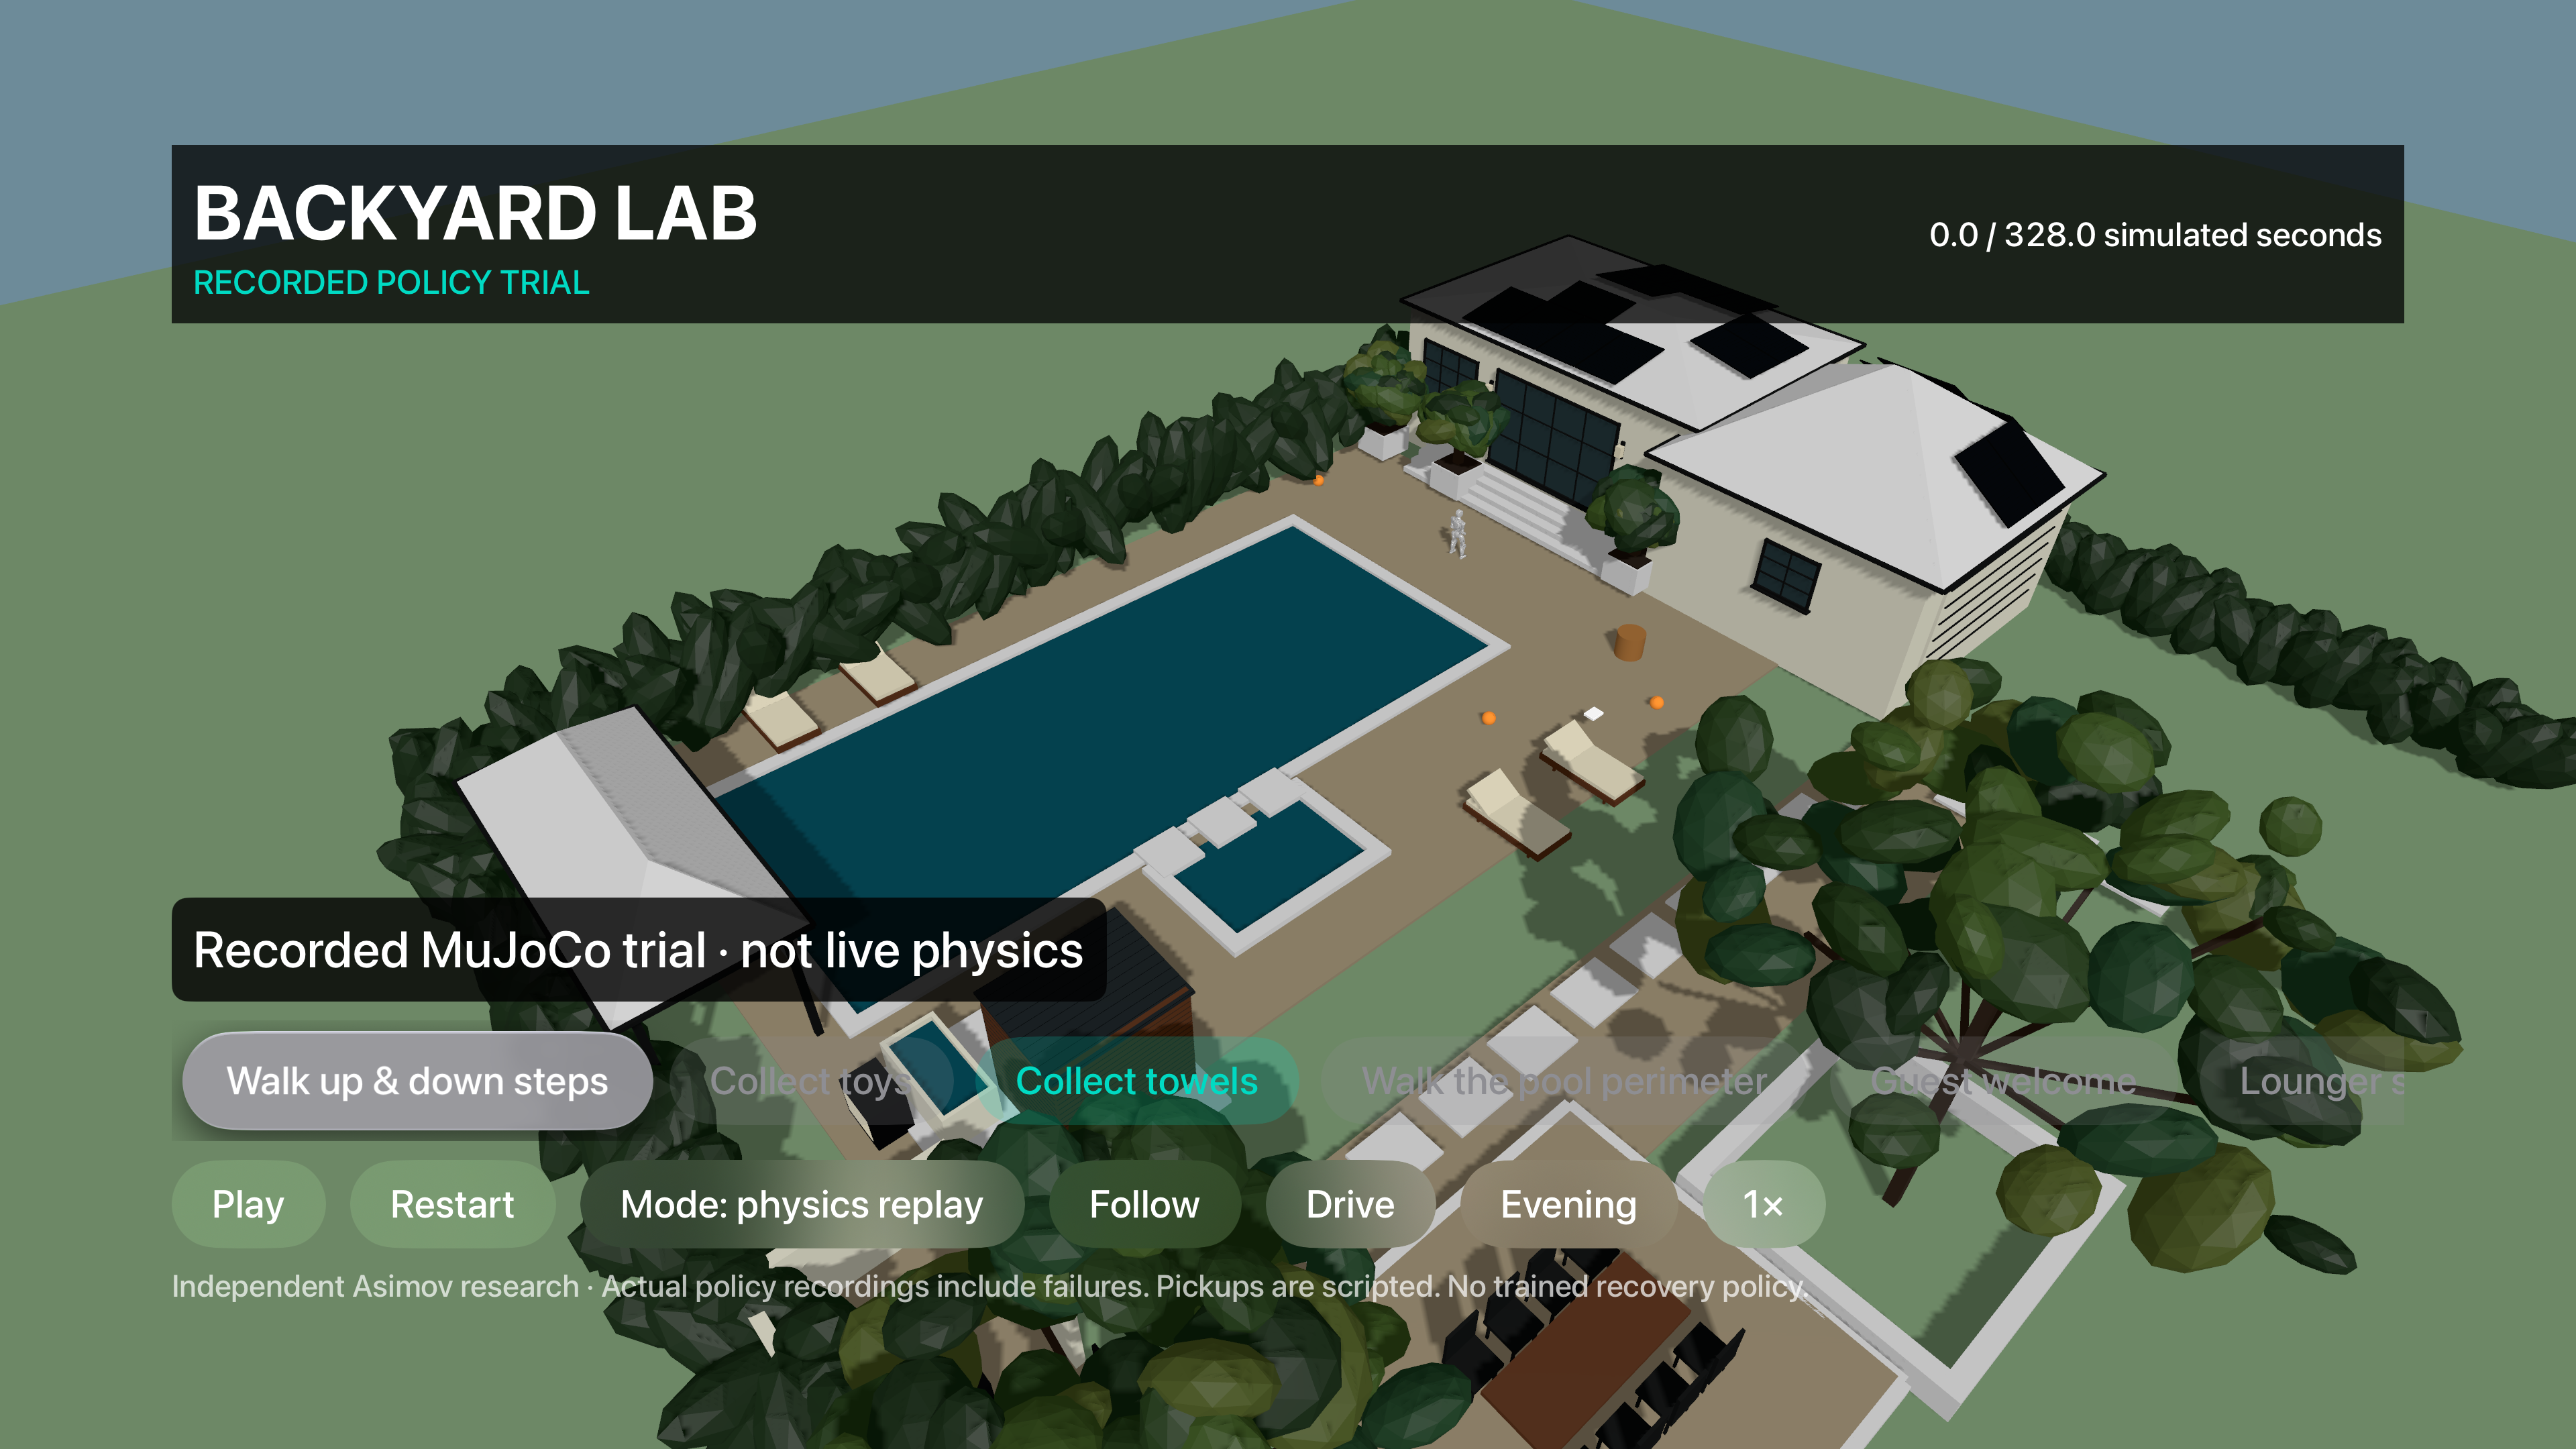
Native Apple TV development capture; the screenshot shows an earlier title. Scripted scenes and recorded MuJoCo trials play locally on Apple TV. There is no live physics or robot control. Robot design: Menlo Research’s Asimov 1; learned trials use Ma-Dan’s community checkpoint.
TestFlight in preparation
There is no public invite yet. This page will link to the approved external build when testing opens.
 Ego capture & teleoperation